

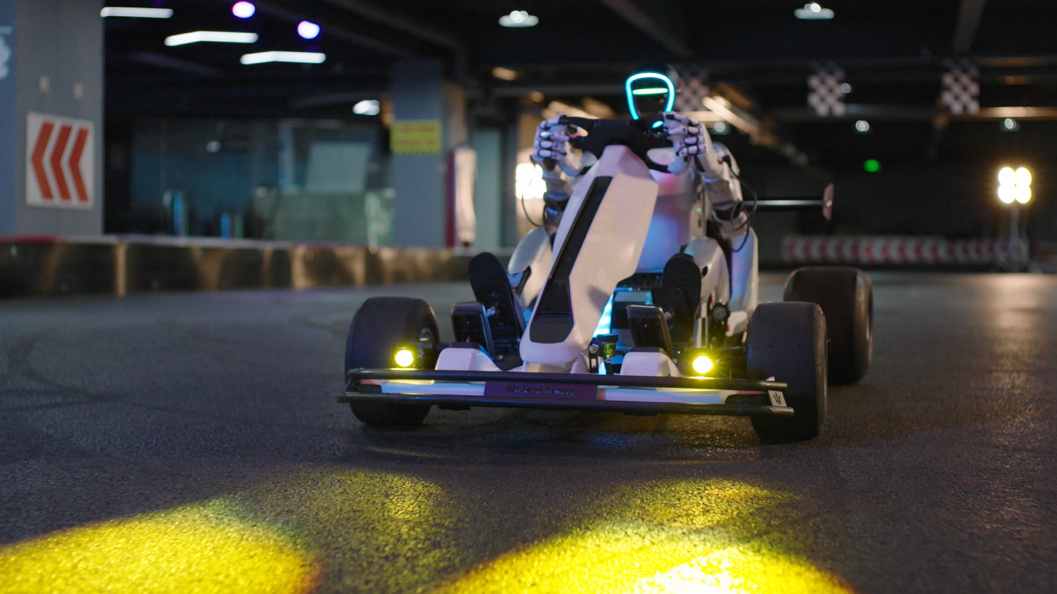
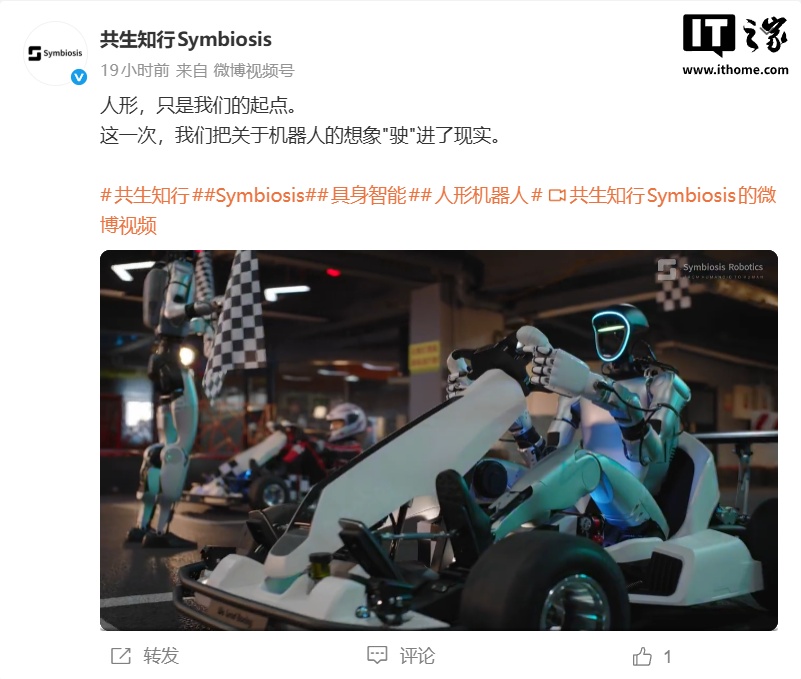
Symbiosis Robotics released a demo yesterday (August 17) showing a bipedal humanoid robot driving a go-kart, and launched its official website at the same time.
This is the first systematic showcase of Symbiosis Robotics' progress in whole-body intelligence for bipedal humanoid robots since the company's establishment. The company said racing is only its first public test, with more examples to come in mobile manipulation, high-precision visual alignment, contact force control, and long-horizon tasks.
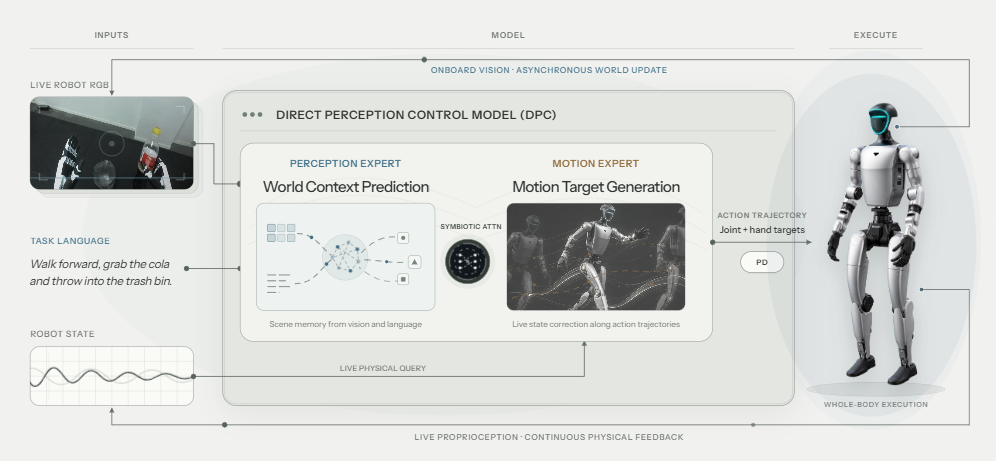
Symbiosis Robotics' official website lists a “Direct Perception — Control Model.” The company said expanded perception helps robots better understand the world, but understanding a task does not automatically mean being able to act reliably. Symbiosis Robotics aims to push the boundary of intelligent models from generating a kinematic target that must be tracked to generating a physical action determined by the body's current state and directly executable.
The Direct Perception Control Model reconstructs the execution chain across three levels: the action interface, representational coupling, and closed-loop training. The model completely removes intermediate motion representations and no longer generates motion references that require an independent Whole-Body Tracker to follow. Instead, it directly maps vision, language, body state, action history, and execution feedback to executable joint and hand targets. Symbiotic Attention allows perceptual and control representations to attend to each other under a shared action objective, constraining task understanding by action feasibility while enabling action generation to continuously leverage semantic context.
With this model, a Unitree humanoid robot achieved hand-eye-foot coordination: it used its right foot to control the accelerator and quickly steered before exiting a turn, combining visual timing, precise throttle control, and driving semantics.
According to AI Tech Review, Symbiosis Robotics was founded by Ding Pengxiang, a doctoral student jointly trained by Zhejiang University and Westlake University, and focuses on end-to-end action generation in embodied intelligence. The company is attempting to address the structural problem in current embodied intelligence architectures where “the model understands the task but action execution is unreliable.”
Technical report:
https://symbiosis-robotics.com/research/dpc/zh/