

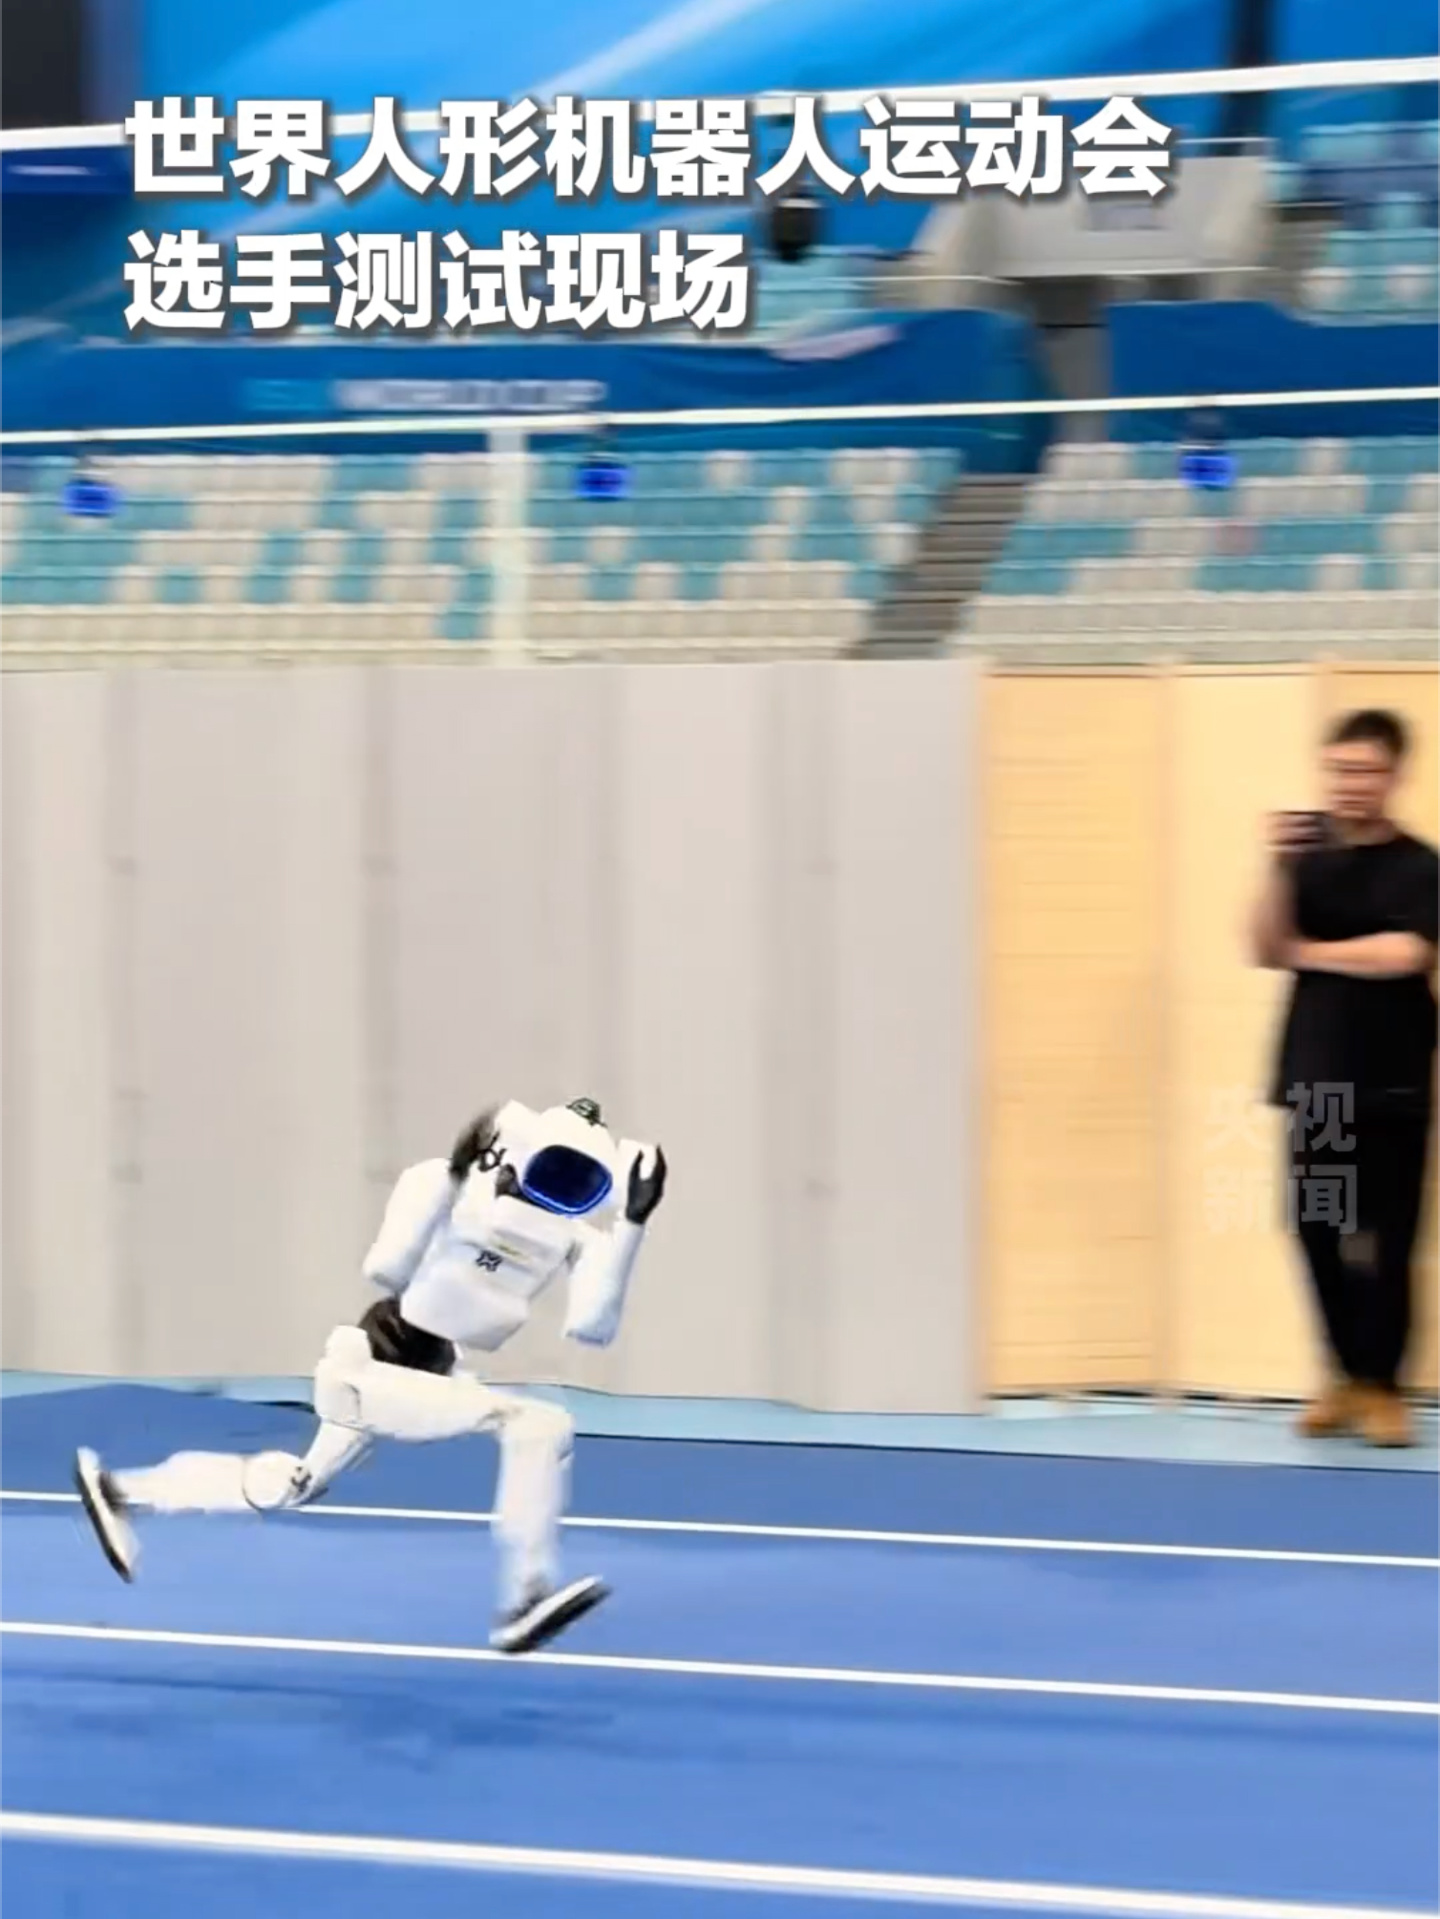
The second World Humanoid Robot Games opened at the National Speed Skating Oval on August 22. In the 400-meter (small group) final, Tiangong won the event in 45.66 seconds, finishing with a “face-covering run.”
According to Hongxing Capital Bureau, after the event, Han Gang, head of the Tiangong Omni 400-meter small-group R&D team and a sports control algorithm expert at the Beijing Humanoid Robot Innovation Center, said in an interview that they did not find a “young girl” for the robot to imitate. The Tiangong Omni came up with the running style through its own “thinking.”
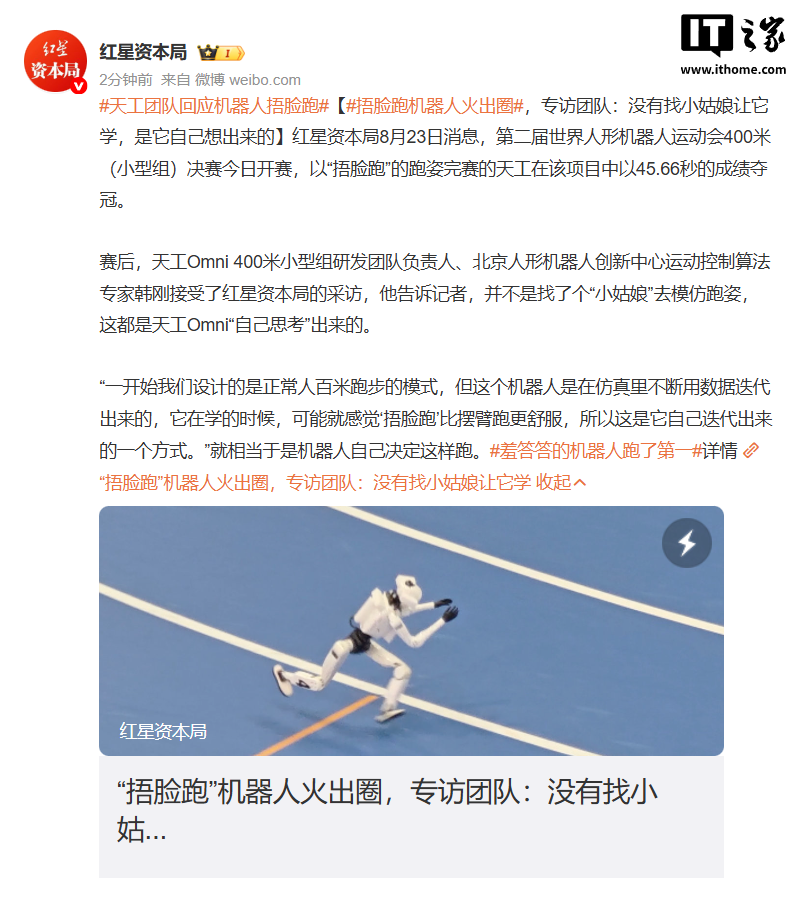
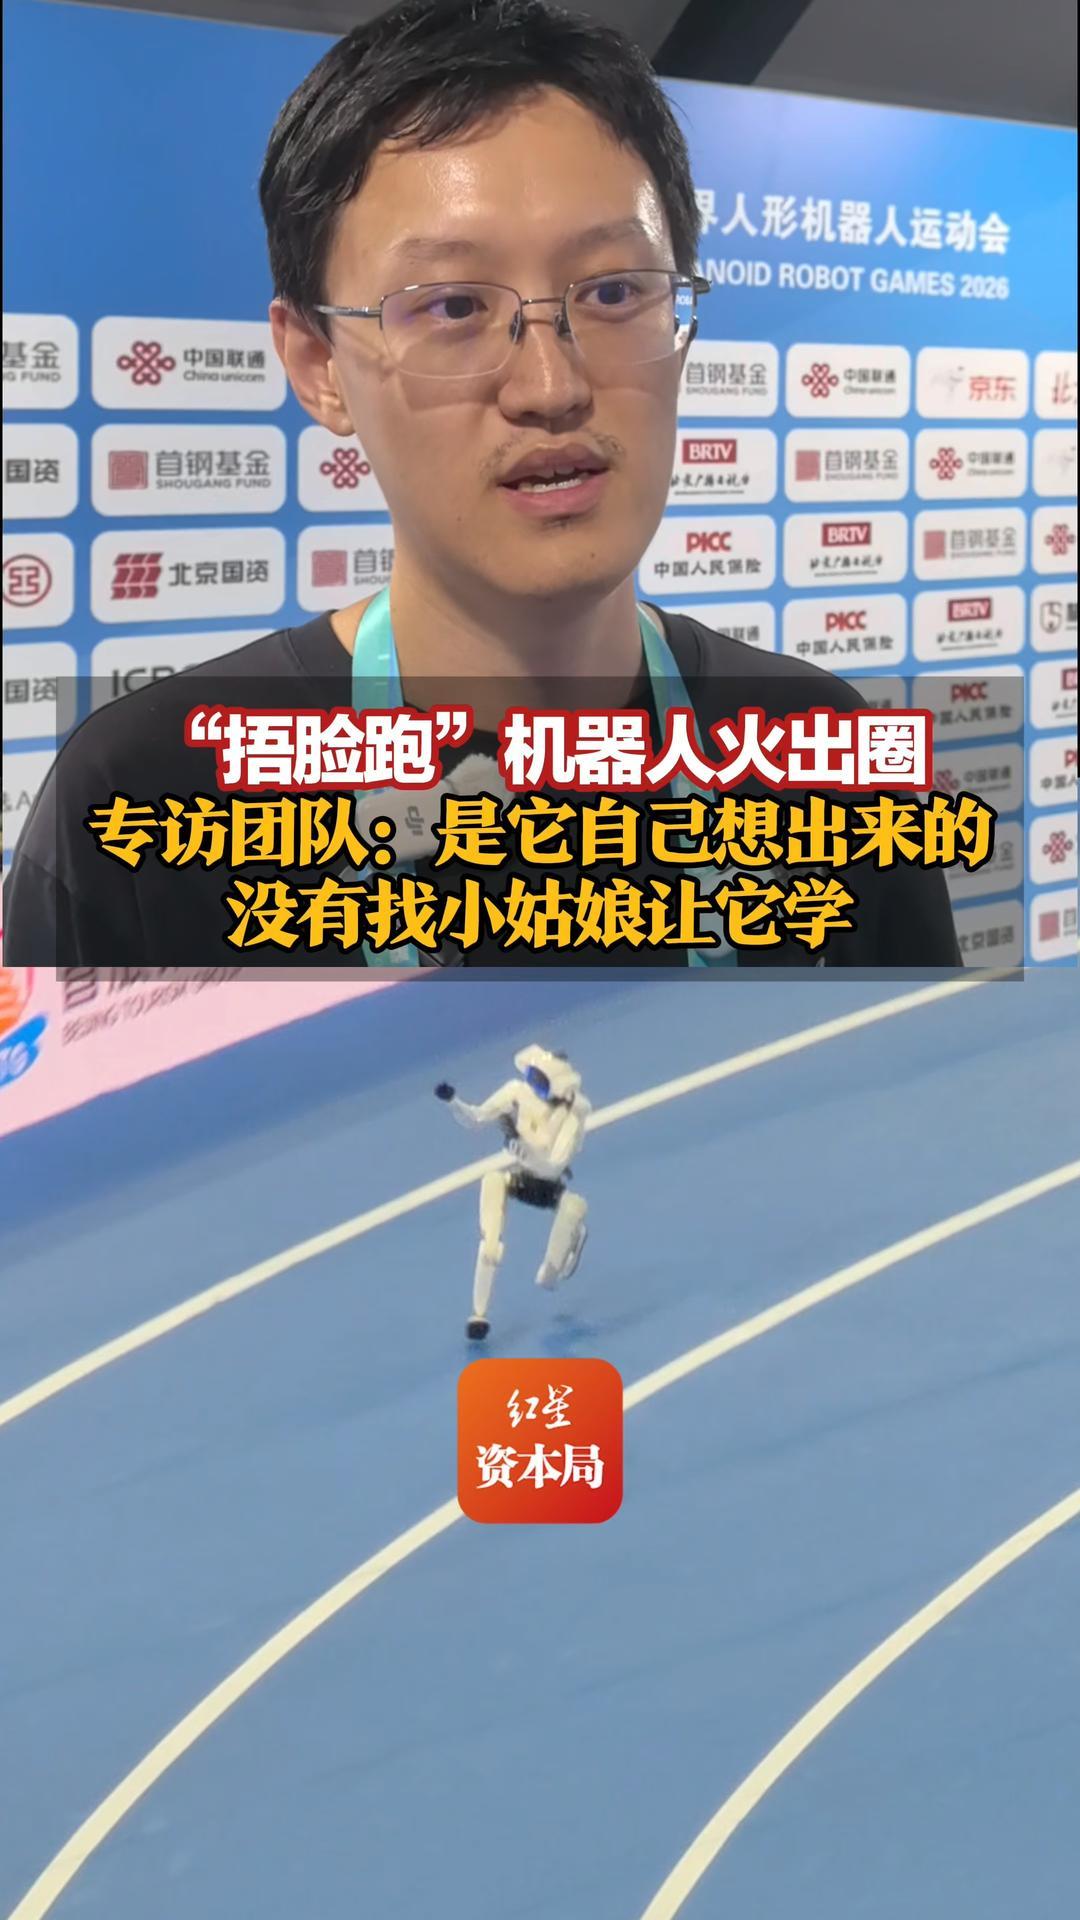
“At first, we designed a normal human 100-meter running pattern. But this robot was developed through continuous data iteration in simulation. While learning, it may have felt that ‘running while covering its face’ was more comfortable than running with arm swings, so this was a method it developed through its own iterations.” In other words, the robot itself decided to run this way.
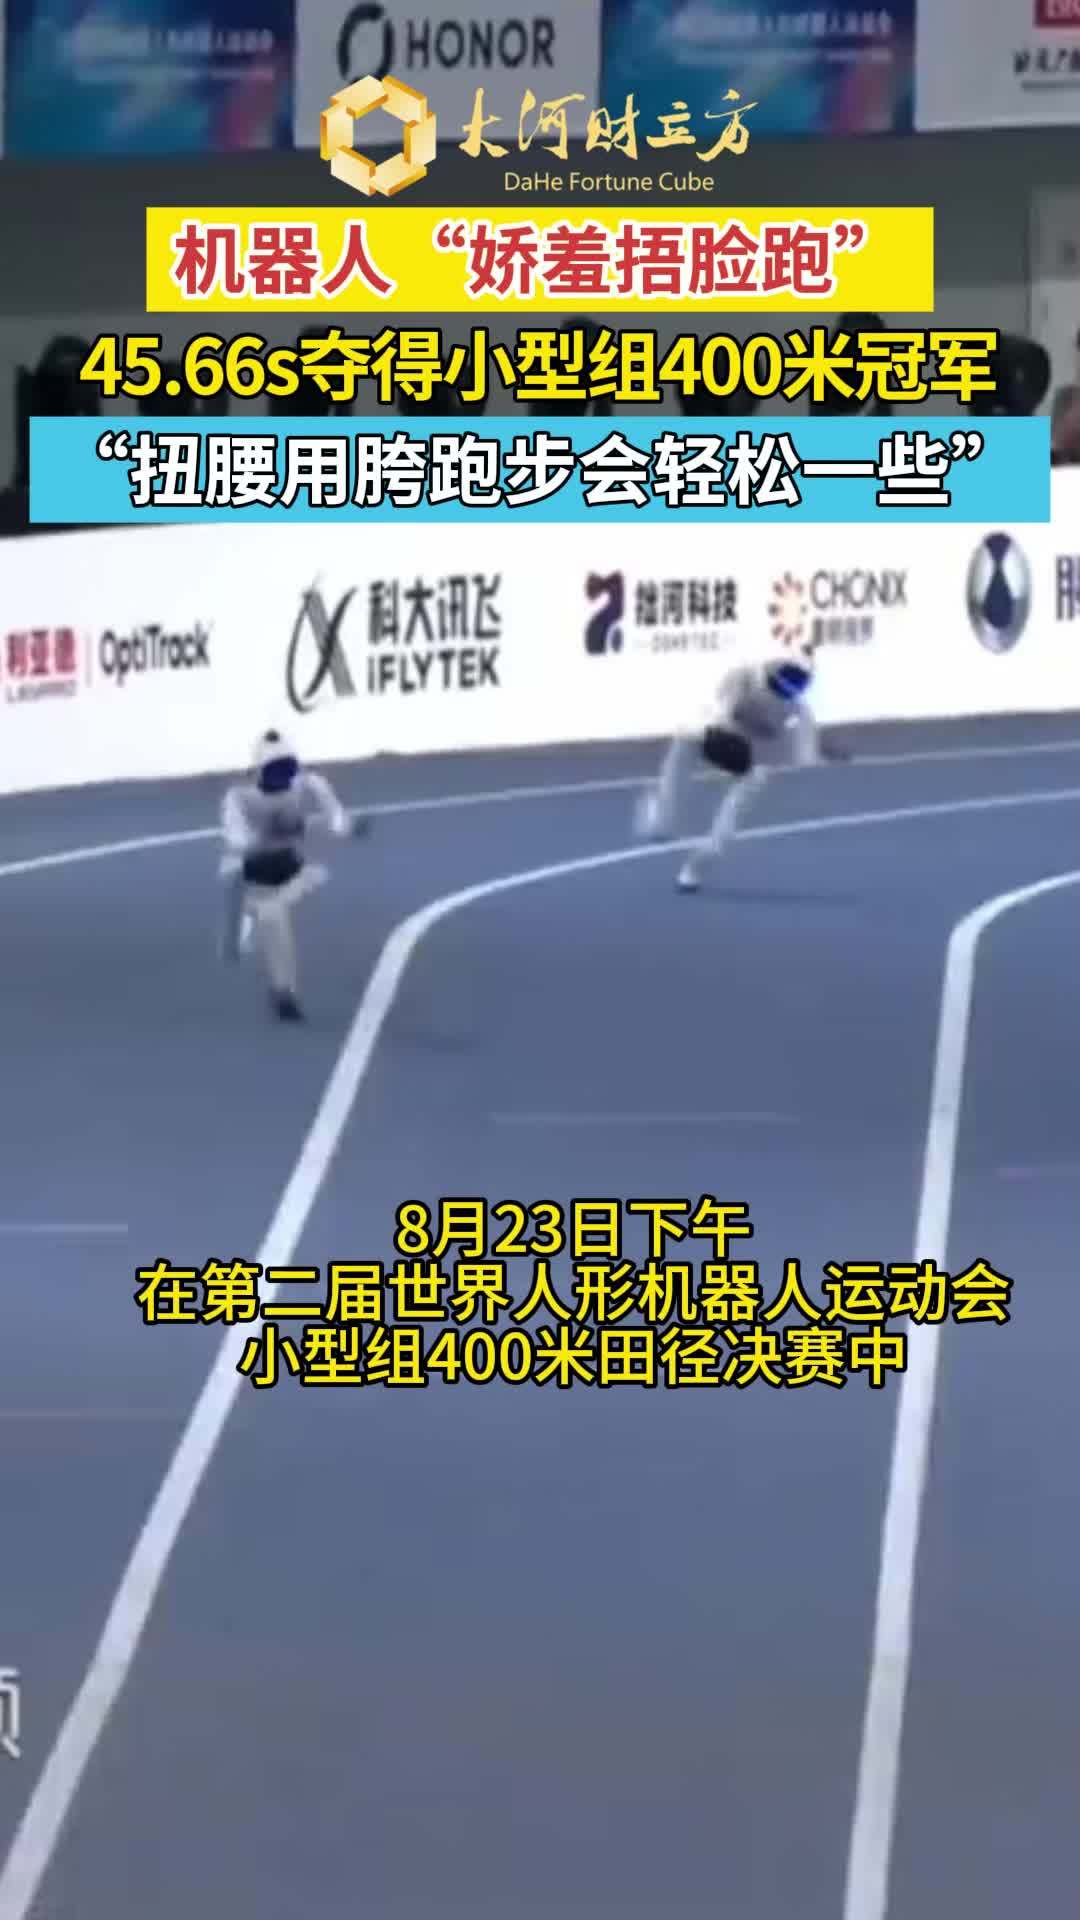
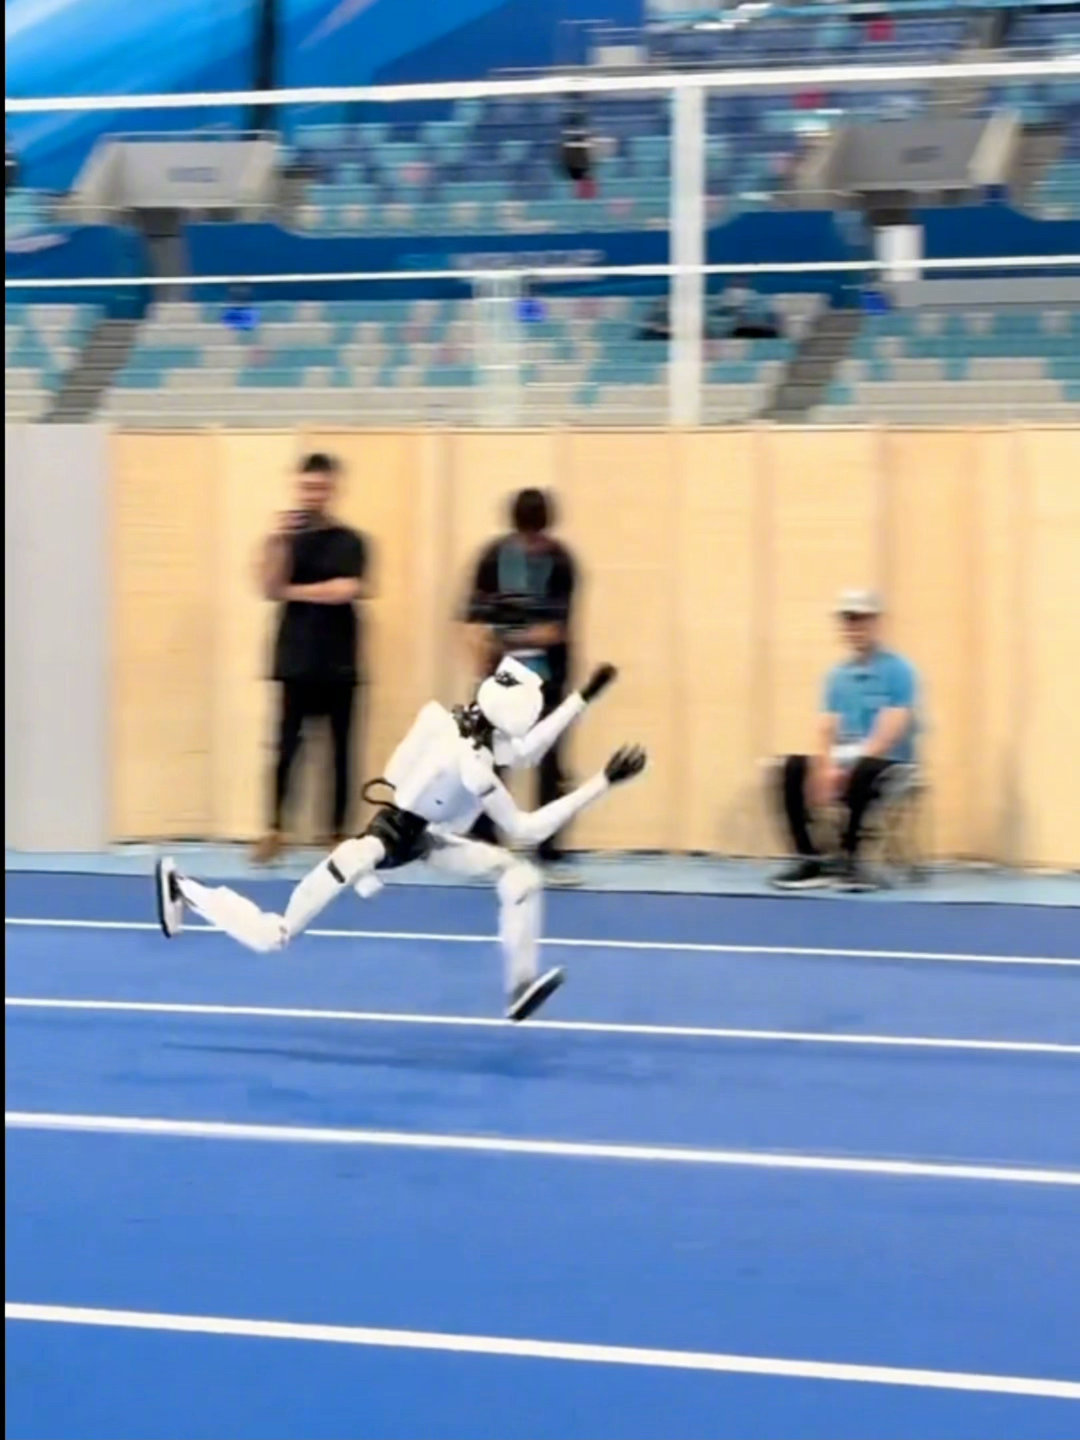
Tiangong Omni is 1.35m tall and weighs 39kg, with a certain load capacity. It is designed for future applications including narrow spaces, emergency rescue, and household services. Notably, it provides a secondary development system, including open APIs for its joints, sensors, system, and motion control, lowering the barriers and costs of underlying R&D for developers and accelerating application innovation and iteration.