

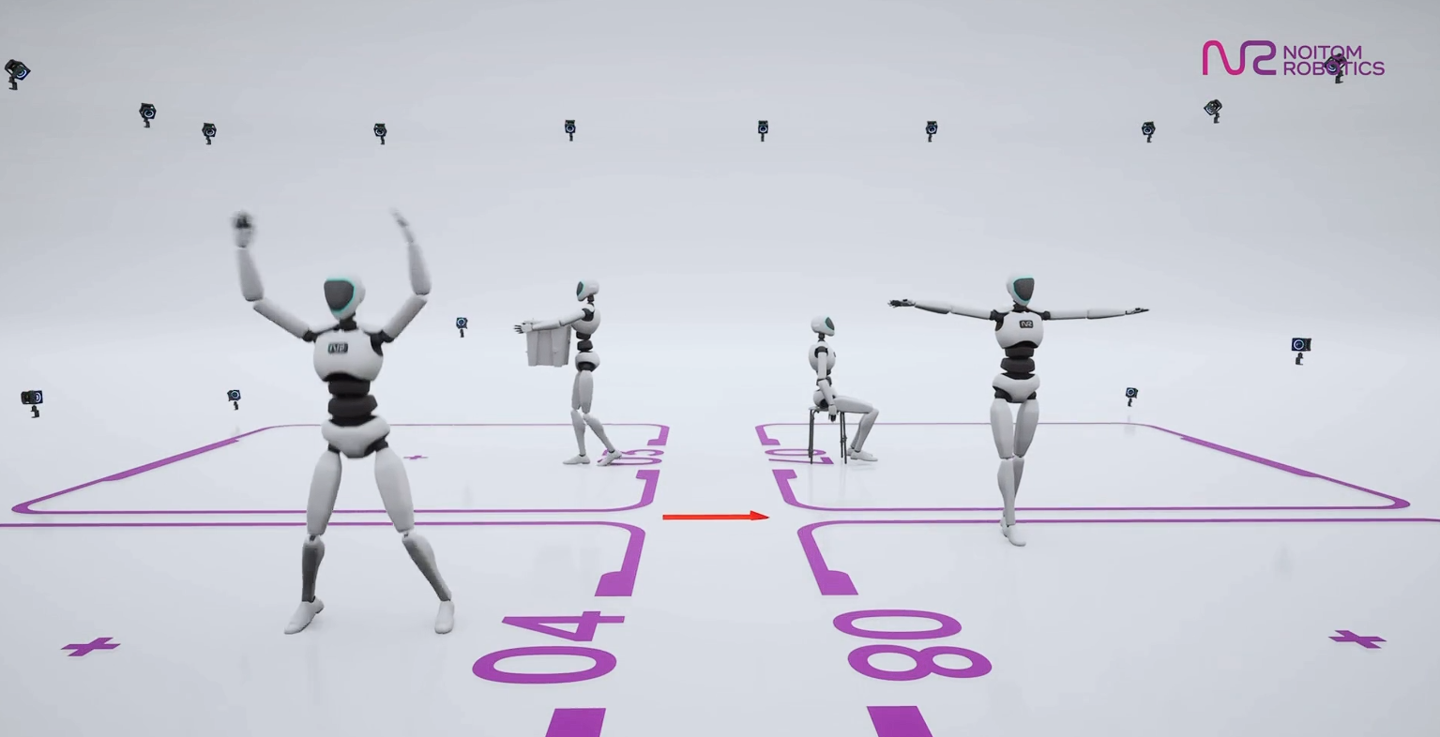
Noitom Robotics released HiPHI during the 2026 World Robot Conference. It is a high-precision optical motion-capture dataset designed for researchers and engineers working in humanoid robot learning, digital humans, and computer graphics.
According to reports, the dataset totals 617.5 hours, including 371.8 hours of full-body human motion data and 245.7 hours of human-object interaction data, with left-right mirroring. The data was collected from 132 motion-capture performers at a frequency of 90 Hz with submillimeter optical motion-capture precision. It was structurally organized into motion units based on FrameNet's framework for organizing the semantics of human actions.
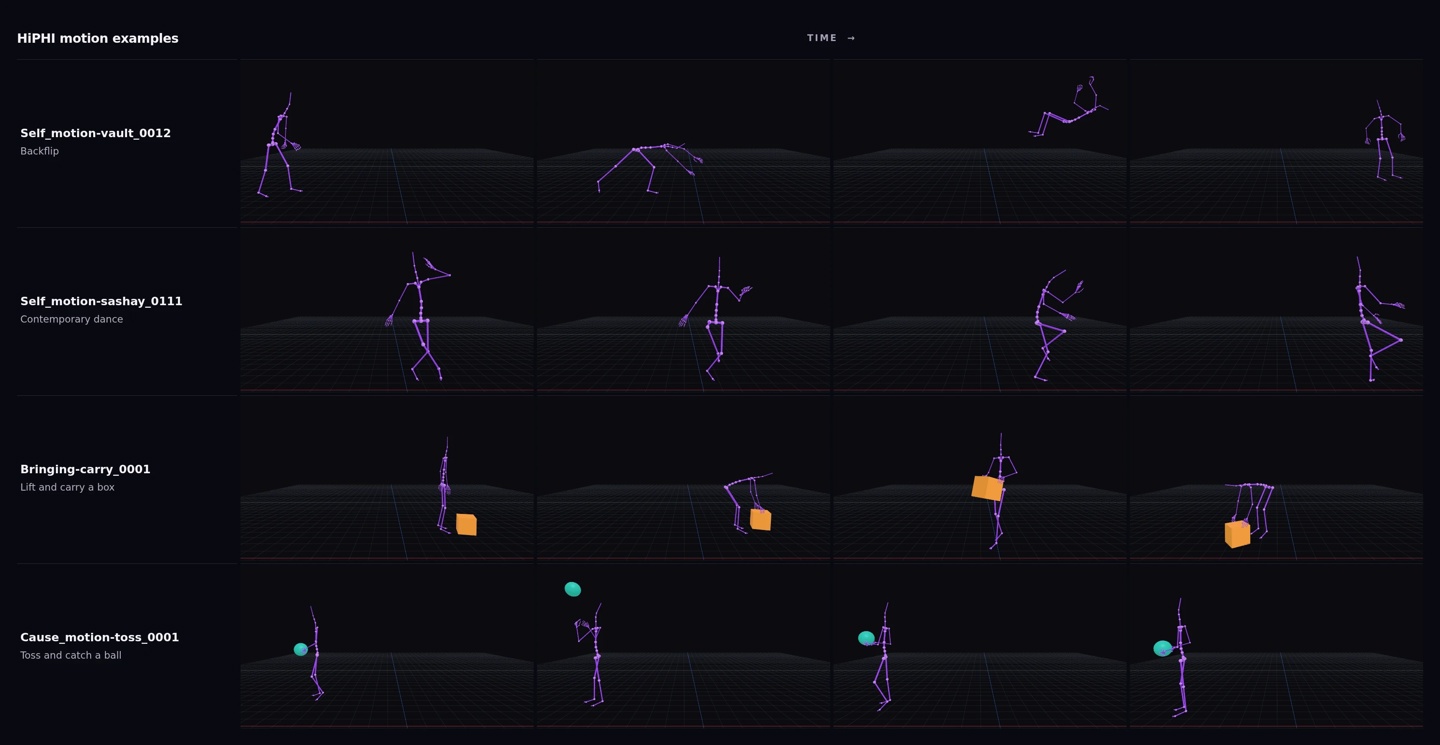
The dataset is now publicly available on Hugging Face, with documentation, a paper, and other resources. Models trained on HiPHI have been deployed on a physical Unitree G1 humanoid robot, enabling actions such as running, sitting down, crawling, carrying boxes, and pulling suitcases.
Reference:
noitomrobotics/HiPHI · Datasets at Hugging Face